机器视觉智能系统套件
视觉测量与检测
很多产线上,尺寸和缺陷仍靠人工判断:抽检几件用量具,其余靠目视过一遍,看着不对才停下来查。产量低时还撑得住,产量一上来就失灵:抽样覆盖不到的漏掉了,同一种痕迹两个人判断不一,等问题确认时一批产品已经做完了。
装相机和传感器不是难点,难的是接下来的一切:图像到手后如何对位、噪声如何处理、测什么、跟哪个限值比、结果如何输出、数据流向哪里、换型时如何避免从零开始。这些问题叠在一起,正是众多视觉项目装完相机却迟迟没有真正跑起来的原因。
锐益视觉测量与检测补齐的正是这一段。这是一套为在线应用打造的视觉测量与检测软件:采集、标定与对位、处理、测量与检测、判定和数据输出配置成一条流程——让产线上的尺寸和缺陷判定从「有人看过」变成「系统判定并留有记录」。
测尺寸还是找缺陷,都在一处完成:从外形尺寸、高度差、平面度、孔位,到划痕、变形、缺件、错装和标签检查——测量与检测在同一软件中配置,输出统一判定,数据回流质量系统。
它是什么
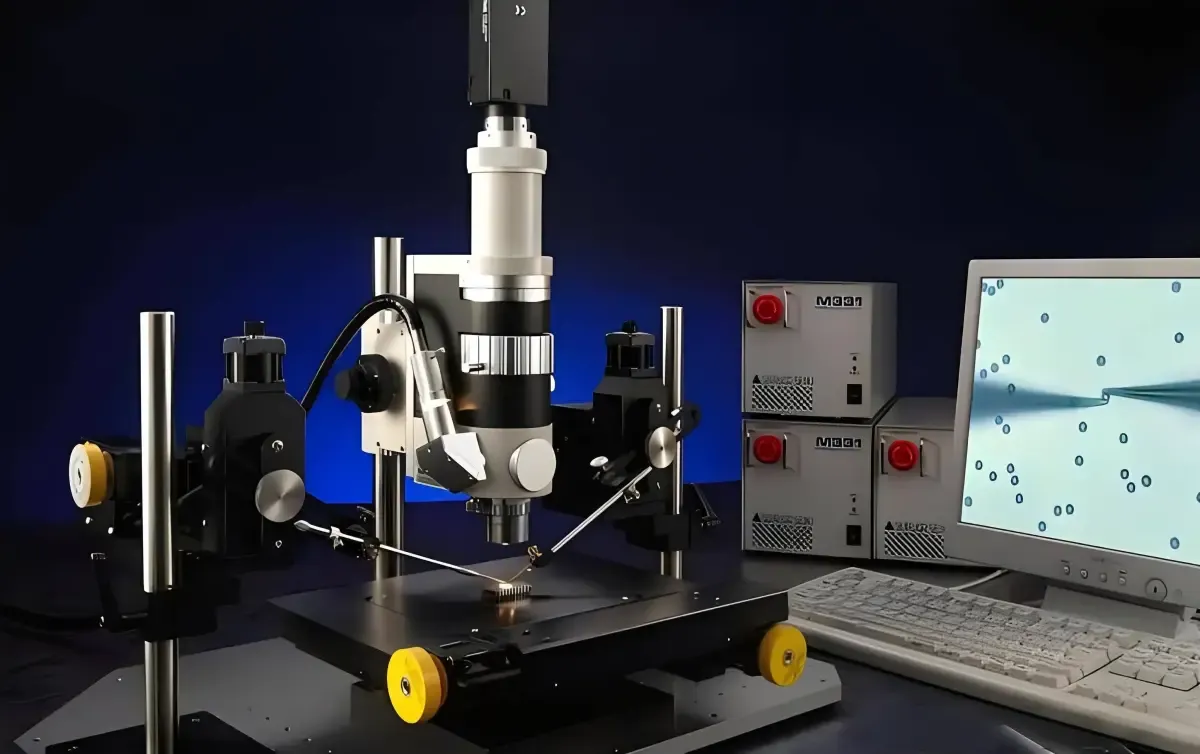
它是运行在产线上的视觉测量与检测软件。相机或传感器采集图像,软件完成对位与处理,执行配置好的测量与检测步骤,输出单项判定和综合判定,并把结果发送给线控系统、质量系统或看板。
Measurement and inspection in one configuration. No need for one software to measure dimensions and another to look for defects. Both kinds of task are arranged in the same project and tuned in the same interface.
Built for in-line use, not offline analysis. It follows the line cycle and returns a judgement per part, feeding back to the line and the quality system as it runs.
Configured rather than rewritten. Measurement items, inspection items, limits and output are all set by configuration and saved as a template — reused on the next variant or the next line instead of rebuilt from scratch.
A result that is more than pass or fail. Each judgement carries the measured value, the basis for the decision, the time and the station, so it can be traced per part and aggregated into yield, distribution and trend.
软件同时支持 2D 与 3D;硬件能做到什么程度,由现场选型决定。The software carries 2D and 3D measurement and inspection algorithms alike. Which items are actually achievable, and to what accuracy and cycle time, is determined by the sensors fitted, the calibration and the available compute. Section 3 covers this in detail.
它测量什么、检测什么
测量
尺寸。零件外形的长、宽、高、间隙、直径与角度。高度与台阶。面到面的高度差、台阶高度以及微小的平面起伏。平面度。在表面多点采样并拟合,判断是否平整、是否在公差内。位置与孔。孔、槽、定位销与螺柱等特征的位置、直径与偏移。截面与轮廓。胶路或涂层的宽度、高度与截面积,并与参考轮廓比对。计数。零件或特征经过时的连续计数。
检测
表面状况。划伤、凹痕、鼓包、污染、变色及类似表面异常。形状与变形。扭曲、翘曲、偏斜、毛刺、崩边与缺损边。装配状态。漏装、错装、反装或错位,以及超差间隙。有无与数量。某物是否存在、有多少、位于何处。胶路与涂层。断胶、溢胶、胶宽或胶高超限,以及漏涂。标识与防错。字符识别、条码与二维码读取,以及核对标签与所贴零件是否相符。
软件与硬件:各自决定什么
这一部分值得直说,因为它决定了一个项目实际能走多远。
What the software provides:在一个界面配置 2D 与 3D 测量和检测算法;覆盖采集、对位、预处理、测量、判定到输出的完整流程;模板项目可在换线和复制产线时复用;并支持结果记录、统计与对外通讯。
硬件决定的部分:
能否做 3D。高度、平面度、截面与体积需要深度信息,因此只有配备 3D 传感器——3D 相机或激光轮廓仪——才能实现。使用 2D 相机时,软件处理平面图像可支撑的内容:尺寸、位置、表面状况、有无与标识。精度上限。可实现的重复性与分辨率取决于传感器分辨率、标定质量、光照与现场条件。传感器给不出的精度,软件造不出来。节拍上限。单件耗时取决于采集速度、数据量与可用算力。视场覆盖。视场多大、整个零件能否纳入,取决于传感器选型与安装——必要时可组合多个传感器扩展。
简单说:软件负责组织能力,使其不被绑死在某一种硬件上;硬件决定这套能力在具体产线上能走多远。测什么、精度目标多少、节拍多快,应在选型时与传感器一并确定——而不是先选软件、把结果交给运气。
应用场景
Application | What is measured or checked | Typical industries |
Flatness and coplanarity | Points sampled across a surface, judged against a flatness tolerance | Automotive parts, electronics and semiconductors, EV battery |
Height difference and step | Small height differences, weld height, stepped surfaces | Electronics and semiconductors, automotive parts |
Dimensions and spacing | Outer length and width, hole pitch, assembly gap, seam width | Mechanical equipment, automotive parts |
Hole and feature position | Position and diameter of holes, slots, locating pins and studs | Mechanical equipment, automotive parts |
Bead and coating | 胶宽、胶高与截面积;断胶和溢胶 | Automotive parts, EV battery |
Assembly completeness | 零件漏装、错装、反装或错位;间隙超差 | Automotive parts, mechanical equipment, appliances |
Surface defects | Scratches, dents, bulges, contamination, discoloration | Across industries |
Presence and counting | Whether a part is there, how many, and where | Across industries |
Marking and mistake-proofing | Characters, barcodes, 2D codes, label checked against the part | Food and beverage, medical, cross-border logistics |
Outer dimensions and volume | Length, width, height and calculated volume | Cross-border logistics, warehousing |
工作原理
Acquire. Images are taken from cameras or sensors on a trigger — an arrival signal, an encoder, a timer or a manual call.
Calibrate and align. A relationship between image and real dimension is established, and each arriving part is position-corrected, so a part sitting slightly off does not move where the measurement is taken.
Pre-process. Denoising, filtering, enhancement and region cropping suppress interference before measurement begins.
Measure and inspect. 按配置运行测量与检测项;需要深度信息的检测项调用 3D 数据。
Judge. Each item is judged against its limit, then an overall judgement is applied by rule — for example, release only when every critical item passes.
Output and record. The result goes to line control or the sorting mechanism in real time, while the record captures measured values, judgement, time and station — available per part or aggregated by batch.
您将获得
软件功能
Feature | 覆盖范围 |
2D and 3D in one | 2D images and 3D data handled in the same software, with measurement and inspection items configured together |
Graphical project setup | Acquisition, alignment, processing, measurement, judgement and output configured through the interface, with typical project templates included |
Calibration and alignment | Sensor calibration, coordinate setup and per-part position correction, keeping the measurement location consistent |
Pre-processing and denoising | Filtering, enhancement and region cropping to deal with site lighting and material variation |
Measurement toolset | Tools for dimensions, height, flatness, position, cross-section and profile |
Inspection toolset | Tools for surface defects, shape, assembly, presence, bead and marking |
Judgement rules | Per-item limits and multi-condition overall judgement, configured per product and operation |
Multiple sensors combined | More than one sensor combined for a wider field of view or multiple angles on a complex part |
Records and statistics | Measured values and judgements stored per part, with query, aggregation, trend and yield reporting |
Industrial communication | Data and signals exchanged with PLCs, line control and quality systems over standard industrial protocols |
Permissions and logs | Parameter changes logged and permissions graded, so judgement criteria cannot be altered casually on the floor |
集成与部署
Line control. Linked to PLCs, sorting mechanisms and rejection devices, with judgement results driving the action directly.
Quality and manufacturing systems. Measured values and judgements written to QMS or MES against batch, operation and equipment, supporting traceability and statistical analysis.
Sensors and cameras. 依据测量项目和精度目标选型;2D 相机与 3D 传感器可组合使用。
Capability layer. Runs on RUIYI Visual CAST, sharing model and device management, compute scheduling and lifecycle governance.
部署模式——本地、边缘或云端——以及集成范围在项目界定阶段商定,通常先从一条产线或一个检测工位做起,再复制到同类产线。